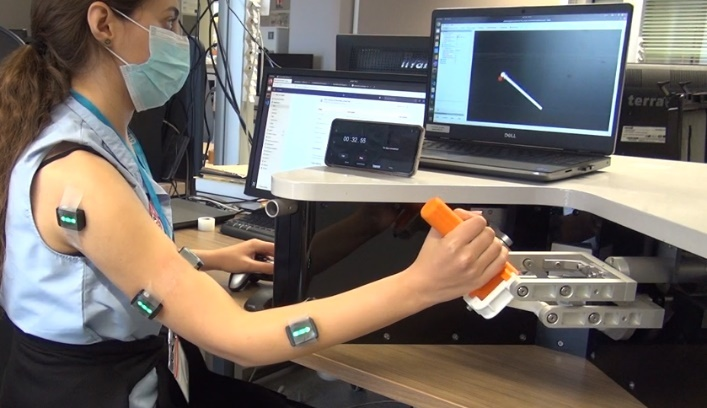
Context
Master project (M2 Medical Robotics) at ICube Laboratory, Université de Strasbourg (Feb–Sep 2022). The goal was to adapt the speed of a haptic rehabilitation task automatically, based on the user's current muscular effort measured via surface EMG — providing less resistance when the user is fatigued and more challenge when they are stronger.
Responsibilities
- EMG acquisition — multi-channel real-time acquisition via the device's analogue inputs
- Signal processing chain — 4th-order Butterworth bandpass filter (20–450 Hz), linear envelope, MVC normalisation
- Event detection — CuSum (CUSUM) change-point algorithm for reliable muscle activation onset/offset detection
- Control implementation — impedance controller developed in C++ under ROS, interfaced with the haptic device via EtherCAT and Maxon EPOS4 motor drives
- Experimental parameter tuning — gain selection via pilot trials with healthy participants
- User study — designed protocol, ran sessions, analysed outcomes
Key Results
- Reliable real-time detection of muscle activation events across all participants
- Automatic adaptation of haptic task speed to user EMG level
- Full EMG-to-command pipeline integrated and validated in the robotic system
- Successful user validation on healthy participants
Technologies
ROS · ROS Control · C++ · Linux · EtherCAT · Maxon Motors · EPOS4 · rqt · rosbag · Impedance control · Python · MATLAB