Projects
Wearable robots, from CAD to control.
Exoskeletons, ROS 2 architectures, EMG-driven assistance, haptics and swarms. Pick a thread.
Exoskeletons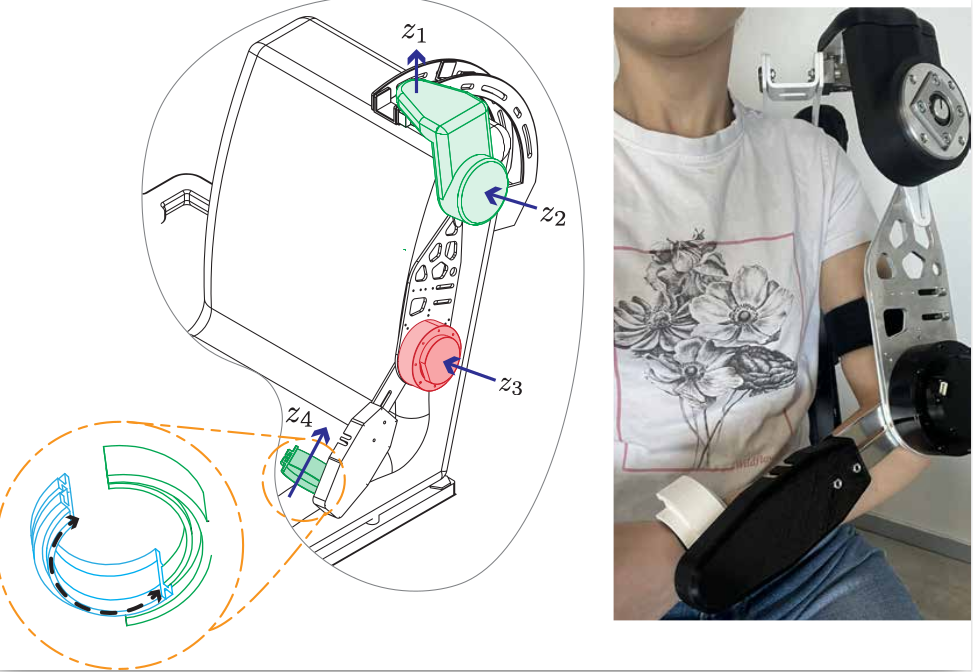 Active Upper-Limb ExoskeletonDesign, mechatronic integration and control of an active elbow exoskeleton for motion assistance and gravity compensation.read moreRobotics software
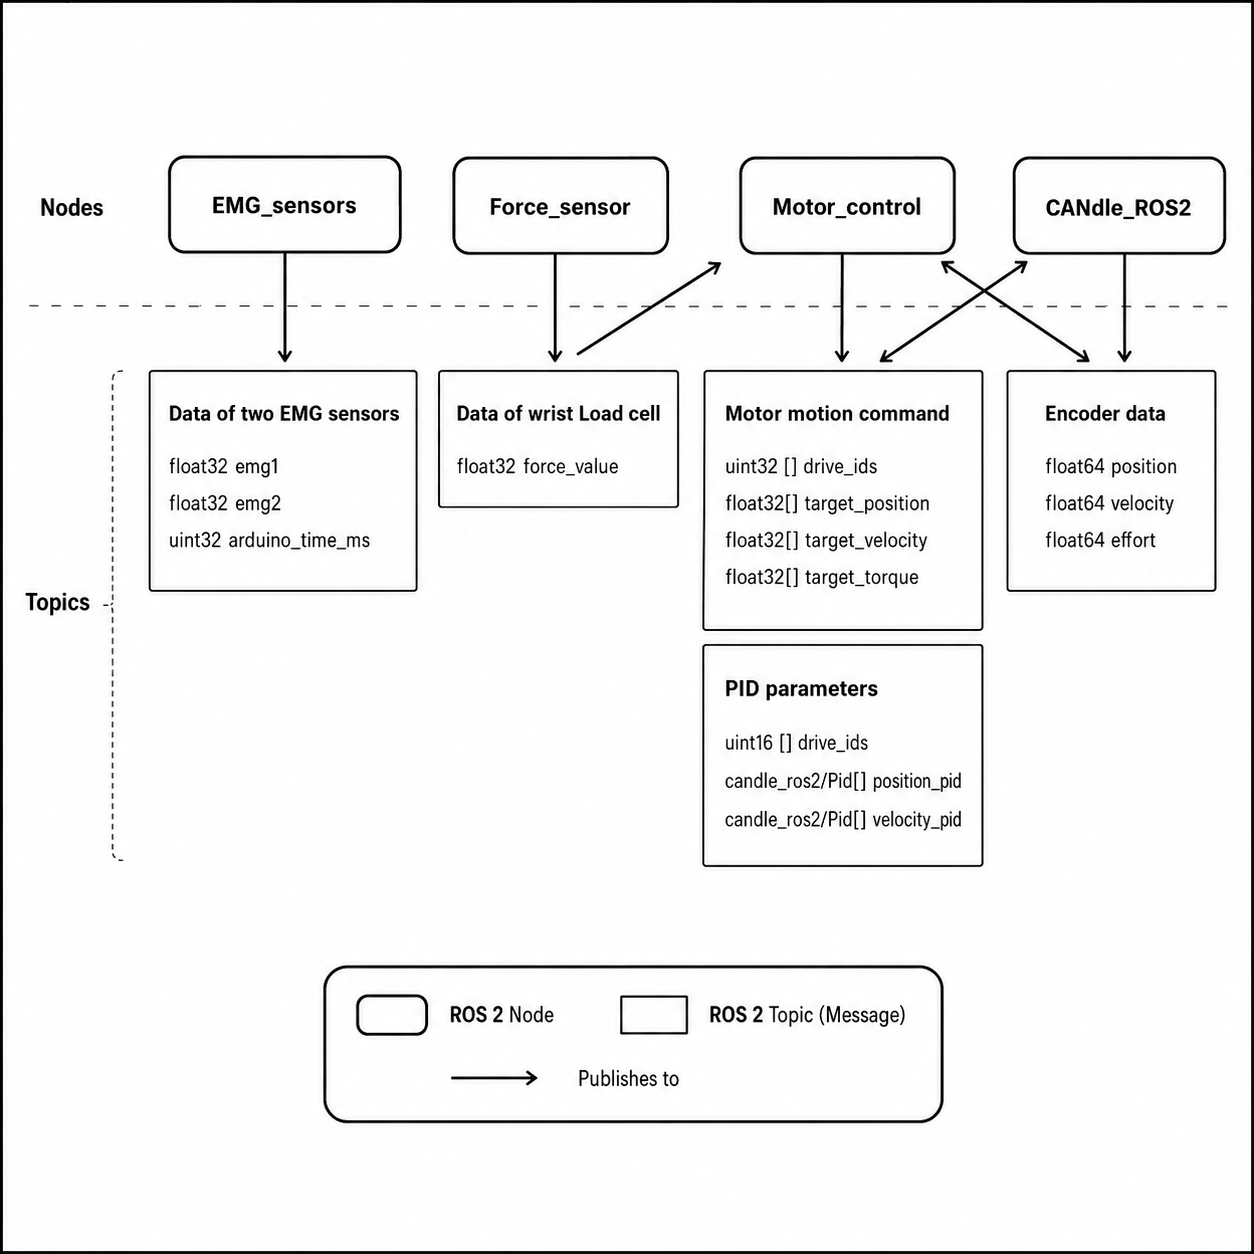 ROS2 Distributed Architecture for ExoskeletonDesign and implementation of a modular, distributed ROS2 software stack connecting motor control, sensors and assistance algorithms.read moreEMG & signal processing
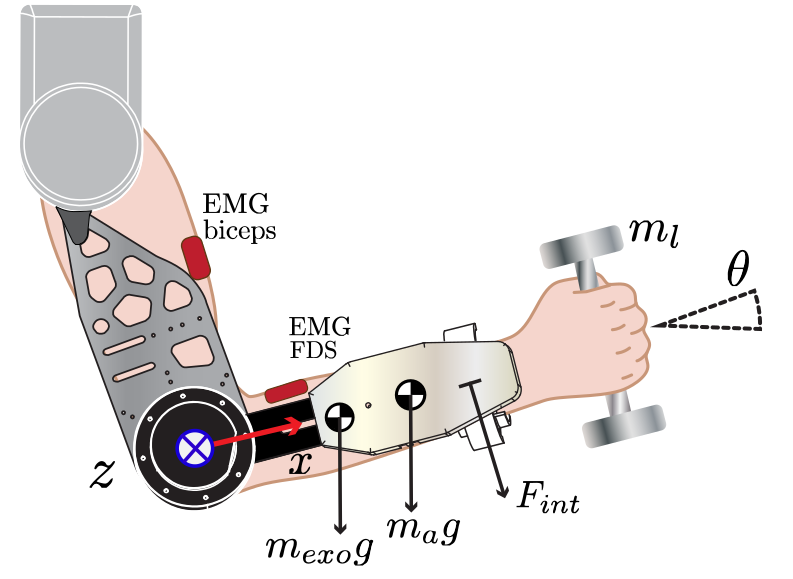 Real-Time Load Estimation from EMGOnline load estimation using surface EMG to automatically adapt exoskeleton assistance — fuzzy-logic approach with per-user calibration.read moreMechanical design
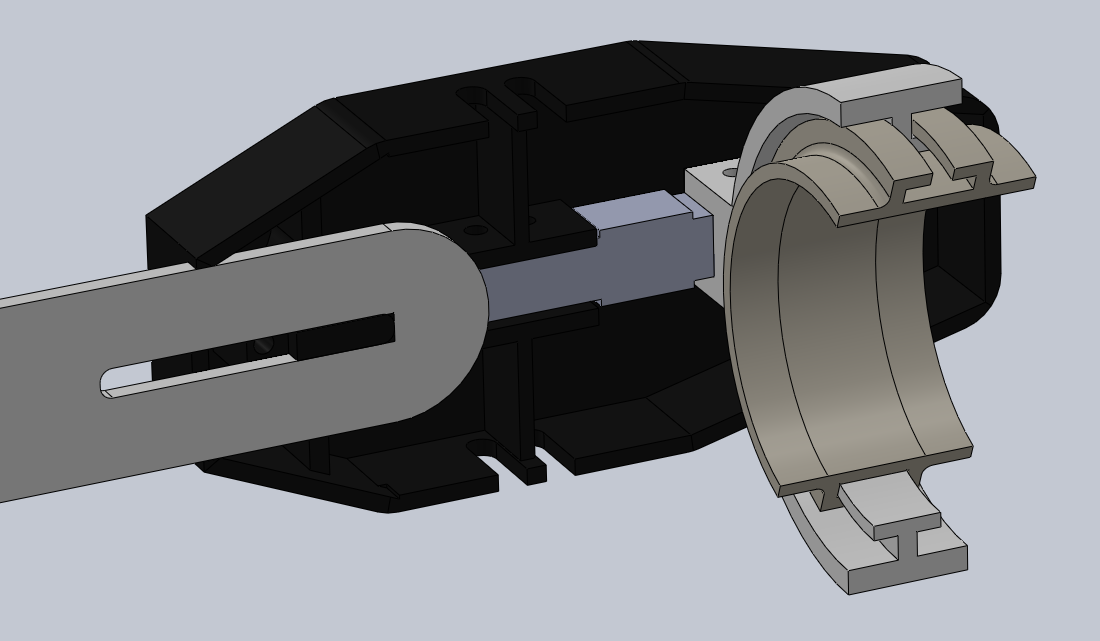 Exoskeleton Mechanical Design (Multi-Generation)Iterative mechanical redesign of the upper-limb exoskeleton — kinematic compatibility, adjustability, passive DOFs at shoulder and wrist.read moreHaptics & rehabilitation
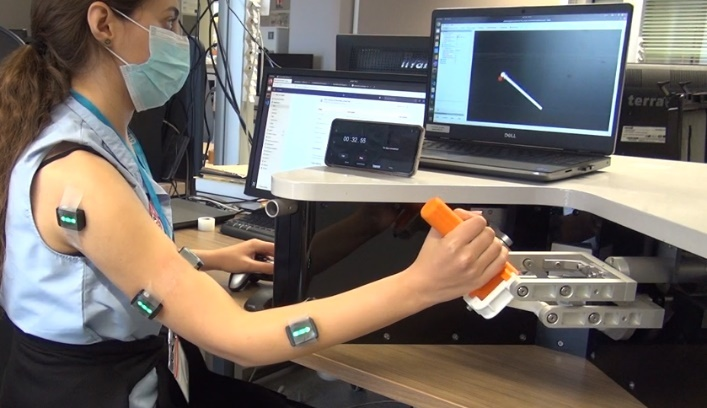 Adaptive EMG-Based Control of a Haptic InterfaceMaster project — real-time EMG-driven adaptive impedance controller for a rehabilitation haptic device (ICube lab, 2022).read moreSwarm robotics
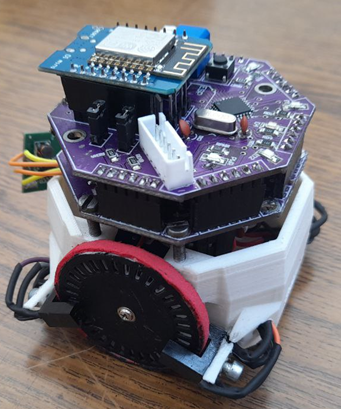 Swarm Robotics — PDE-Based Motion PlanningDiplôme d'Ingénieur graduation project — full hardware build of a 15-robot swarm (7×7 cm each) and a novel fluid-dynamics PDE path planner, benchmarked against APF and graph-based methods over 2000 experiments.
read more
Active Upper-Limb ExoskeletonDesign, mechatronic integration and control of an active elbow exoskeleton for motion assistance and gravity compensation.read moreRobotics softwareROS2 Distributed Architecture for ExoskeletonDesign and implementation of a modular, distributed ROS2 software stack connecting motor control, sensors and assistance algorithms.read moreEMG & signal processingReal-Time Load Estimation from EMGOnline load estimation using surface EMG to automatically adapt exoskeleton assistance — fuzzy-logic approach with per-user calibration.read moreMechanical designExoskeleton Mechanical Design (Multi-Generation)Iterative mechanical redesign of the upper-limb exoskeleton — kinematic compatibility, adjustability, passive DOFs at shoulder and wrist.read moreHaptics & rehabilitationAdaptive EMG-Based Control of a Haptic InterfaceMaster project — real-time EMG-driven adaptive impedance controller for a rehabilitation haptic device (ICube lab, 2022).read moreSwarm roboticsSwarm Robotics — PDE-Based Motion PlanningDiplôme d'Ingénieur graduation project — full hardware build of a 15-robot swarm (7×7 cm each) and a novel fluid-dynamics PDE path planner, benchmarked against APF and graph-based methods over 2000 experiments.
read more