Context
Graduation project for the Diplôme d'Ingénieur en Mécatronique, Université de Lattaquié (Sep 2020 – Jul 2021). The goal was to develop a computationally efficient, collision-free path planner for a fleet of non-holonomic robots, and to validate it on a custom-built physical swarm platform.
What Was Built
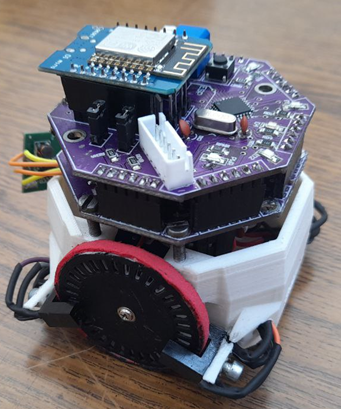
- 15 differential-drive robots designed and assembled from scratch — 7×7 cm footprint, custom PCB, onboard motor drivers, encoders and power management
- Centralised ROS control — overhead stereo camera provides position feedback for all agents; host computer runs the planner and dispatches velocity commands
- PDE-based path planner — solves the steady-state Navier-Stokes equations numerically to generate a smooth velocity vector field; robots follow the field gradient to reach their goals with no local minima and guaranteed path-finding
{% include figure.liquid loading="eager" path="assets/img/nada/swarm_project/swarm_robot_photo.png" title="Assembled swarm robot (7×7 cm)" class="img-fluid rounded z-depth-1" %}
{% include figure.liquid loading="eager" path="assets/img/nada/swarm_project/swarm_heatmap.png" title="Performance heatmap — PDE vs APF vs Graph over 2000 experiments" class="img-fluid rounded z-depth-1" %}
Left: one of the 15 assembled robots. Right: route performance metric across 2000 simulation experiments in 20 maps — hotter colours indicate worse performance, black cells indicate planner failure. The PDE planner records zero failures across all runs.
Key Results
- 0 path-planning failures across 2000 experiments (20 maps × 100 start/goal pairs)
- Outperformed both APF (local minima failures) and graph-based search (lower path quality scores) across all map configurations
- Produced smooth, curvature-continuous paths directly executable by the non-holonomic robots
- Full working swarm platform delivered: hardware, firmware, ROS stack and planner integrated and validated
Technologies
ROS · C++ · Python · MATLAB · SolidWorks · Custom PCB · Stereo camera · Navier-Stokes PDE · Numerical simulation · Linux